Learn what dexterous manipulation means, why timing and contact data are key, and how multimodal datasets train reliable robot-hand policies
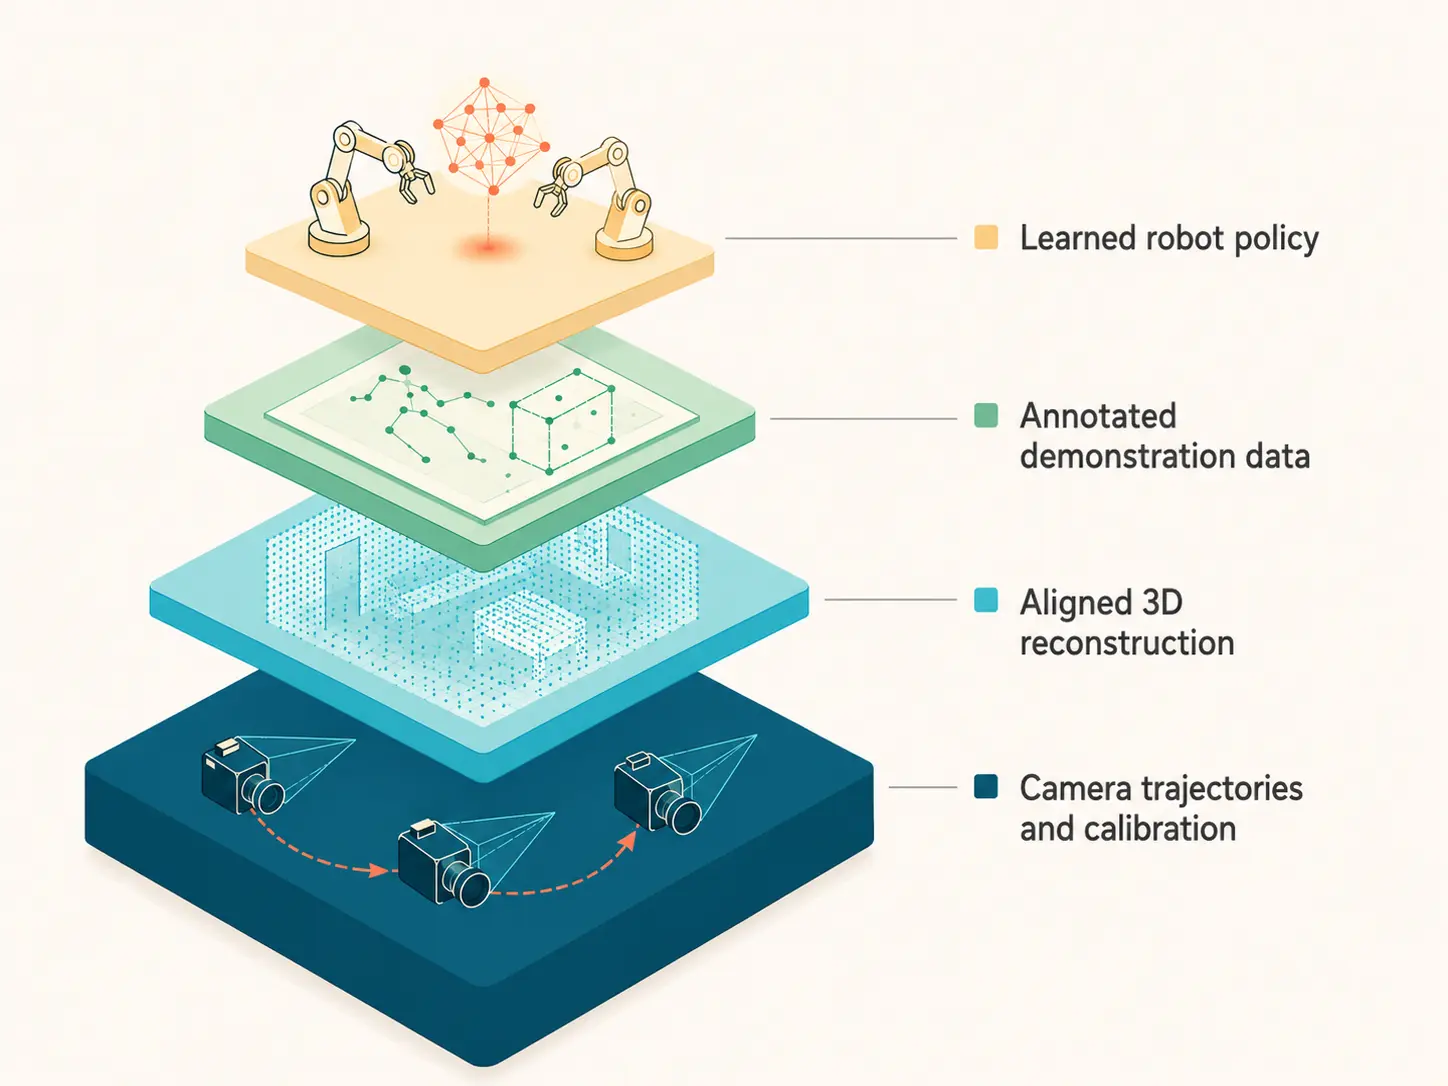
See how we built a SLAM robotics pipeline that turns bimanual demonstrations into reliable camera trajectories, and why ORB-SLAM3 alone wasn't enough.
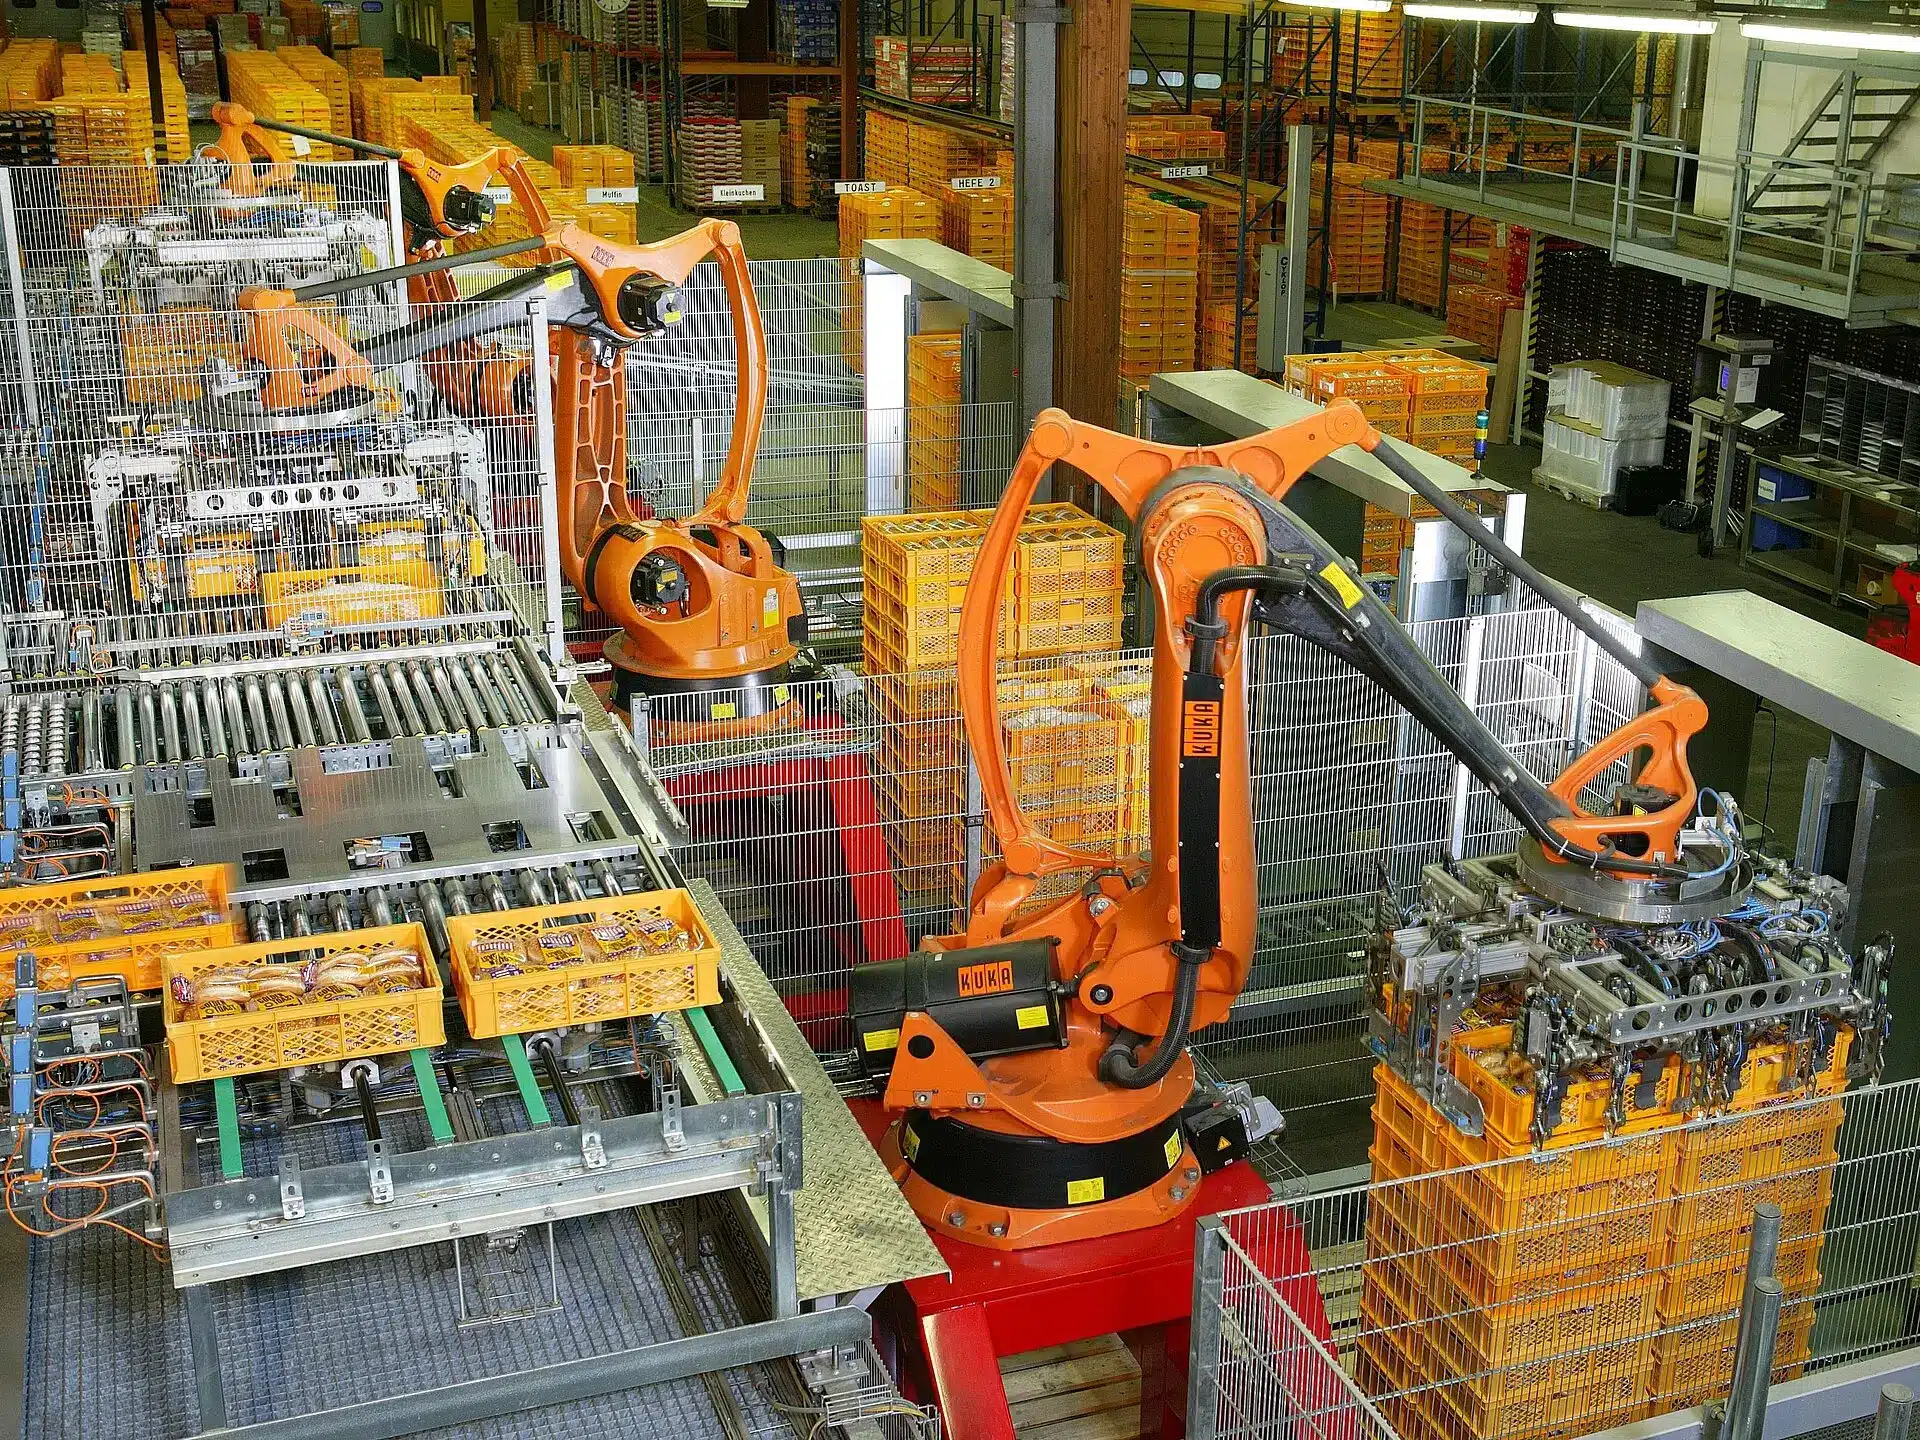
Explore real-world applications of robotics across warehouses, factories, farms, and aerospace, and learn how physical AI and high-quality data power intelligent robots.
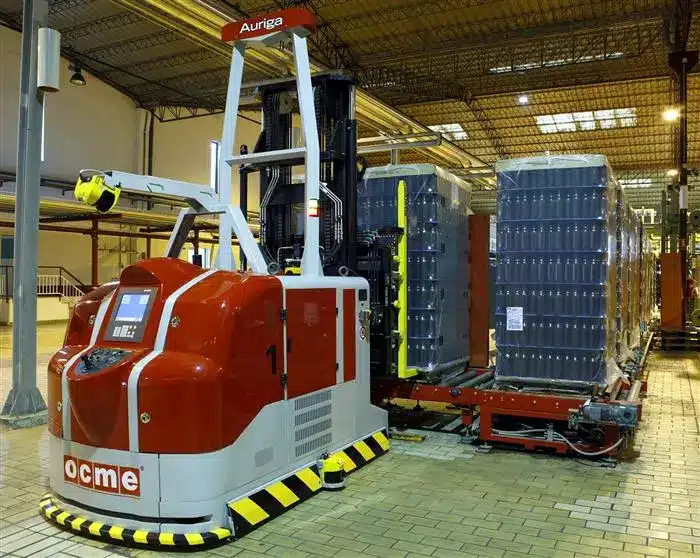
Discover how warehouse robots learn from teleoperation data to handle real-world warehouse automation

Learn what a mocap suit is, how wearable motion capture works, and why suit-captured movement has become crucial training data for robots

See how reinforcement learning works in robotics, how teleoperation data feeds and stabilizes it, and what it takes to turn that data into reliable robot...

See what mocap is, how motion capture works, and why it has become an essential part of training data for cutting-edge robots and physical AI
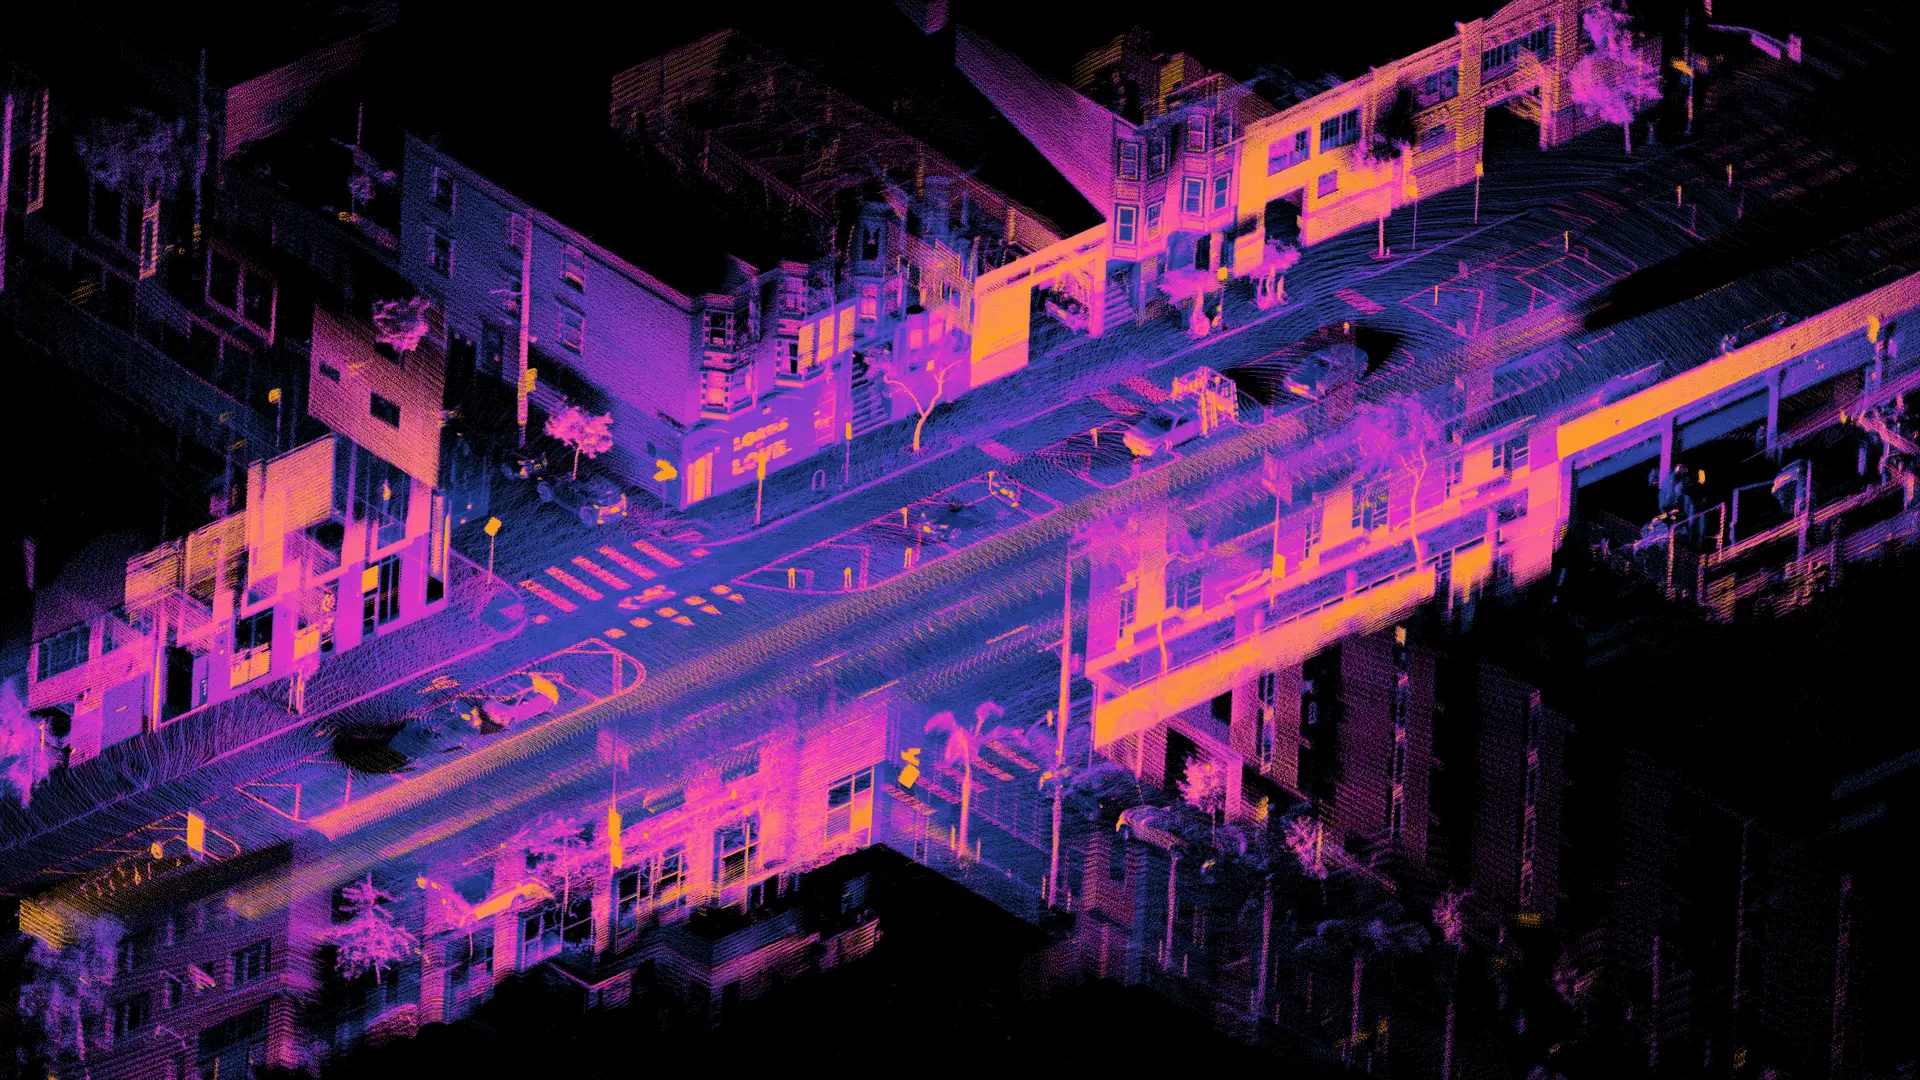
Learn what 3D point cloud annotation is, how it powers robotics perception, and why spatial AI depends on accurate 3D training data.