
Autonomous Systems
August 28, 2026
Learn why some humanoids use lidar robotics while others rely on cameras, how each sensor compares, and what that choice means for robot training data.
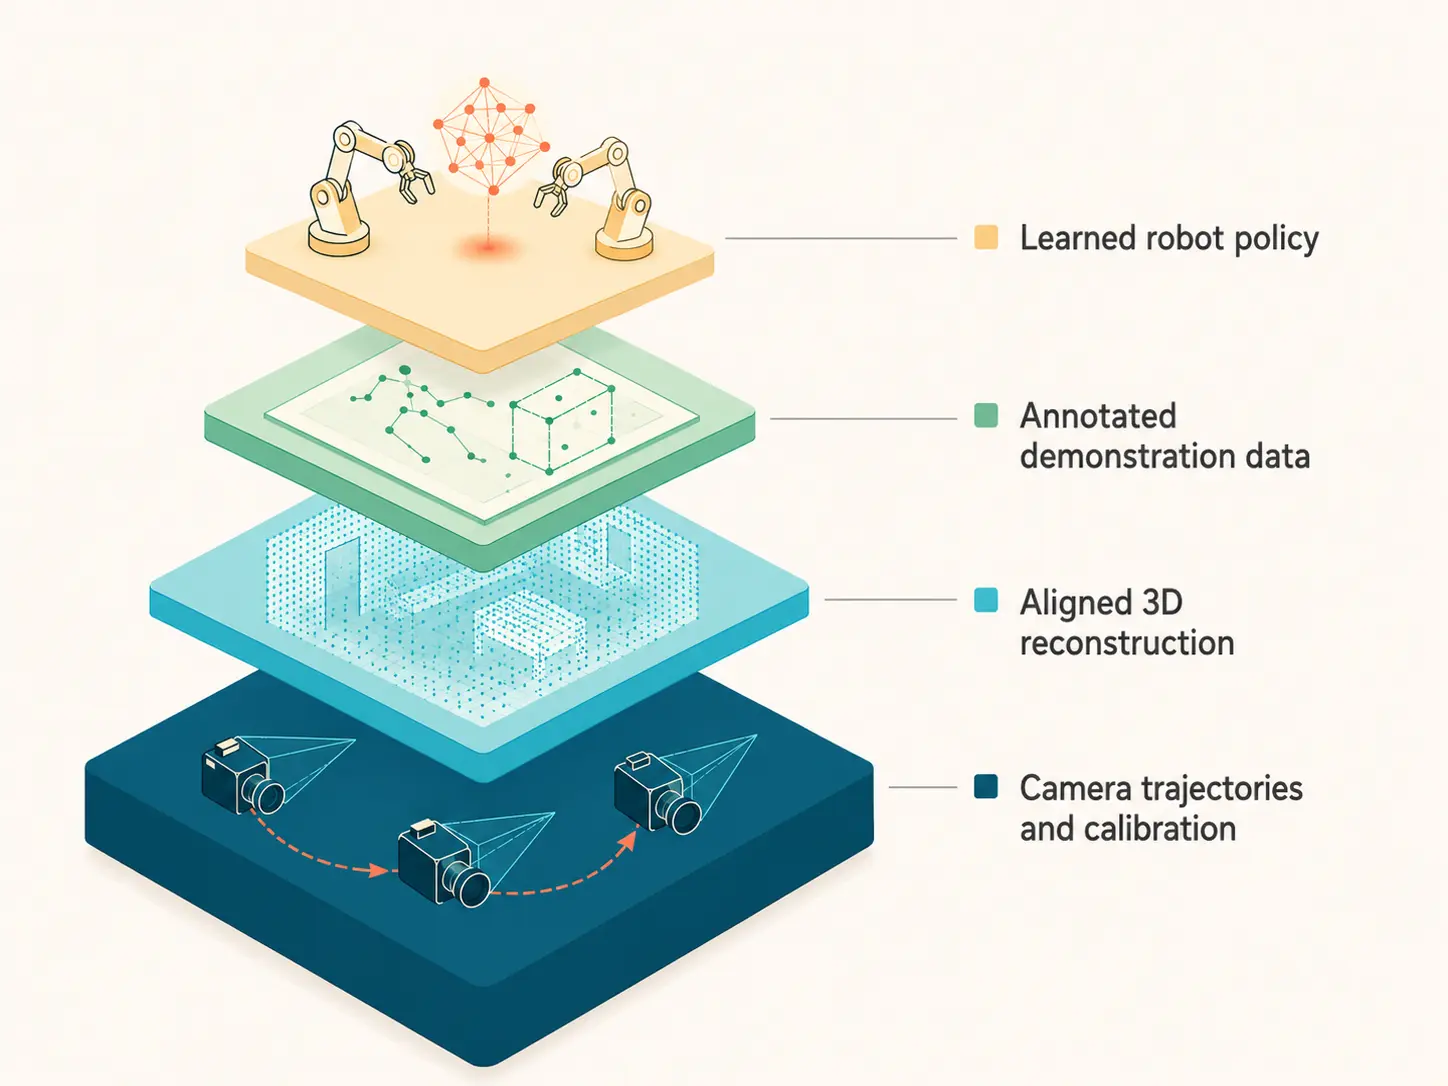
See how we built a SLAM robotics pipeline that turns bimanual demonstrations into reliable camera trajectories, and why ORB-SLAM3 alone wasn't enough.
Explore why evaluating a vision language action model is so hard, which benchmarks teams use today, and what a credible benchmark report should contain.
Explore the 7 core physical AI annotation types and learn how high-quality labels help robots understand, learn, and perform real-world tasks.
Explore real-world applications of robotics across warehouses, factories, farms, and aerospace, and learn how physical AI and high-quality data power intelligent robots.
Discover how warehouse robots learn from teleoperation data to handle real-world warehouse automation

Learn what a mocap suit is, how wearable motion capture works, and why suit-captured movement has become crucial training data for robots

See how reinforcement learning works in robotics, how teleoperation data feeds and stabilizes it, and what it takes to turn that data into reliable robot...

See what mocap is, how motion capture works, and why it has become an essential part of training data for cutting-edge robots and physical AI